Make the geometry work.
Passage direction, plate alignment, separate fluid paths, seals and the nozzle interface all have to agree in the assembly.
High school student. Hands-on builder.
I'm a sophomore at Rock Canyon High School interested in aerospace engineering, robotics and programming. Explore my projects, engineering decisions and work in progress.
A reusable rocket.
Built from first principles.
Stratum is entirely my own project: a reusable vertical-takeoff-and-landing demonstrator, from the engine design to the software used to explore it.
I'm working through the engineering at the component level: injector geometry, manufacturing constraints, interfaces and the analysis that connects them.
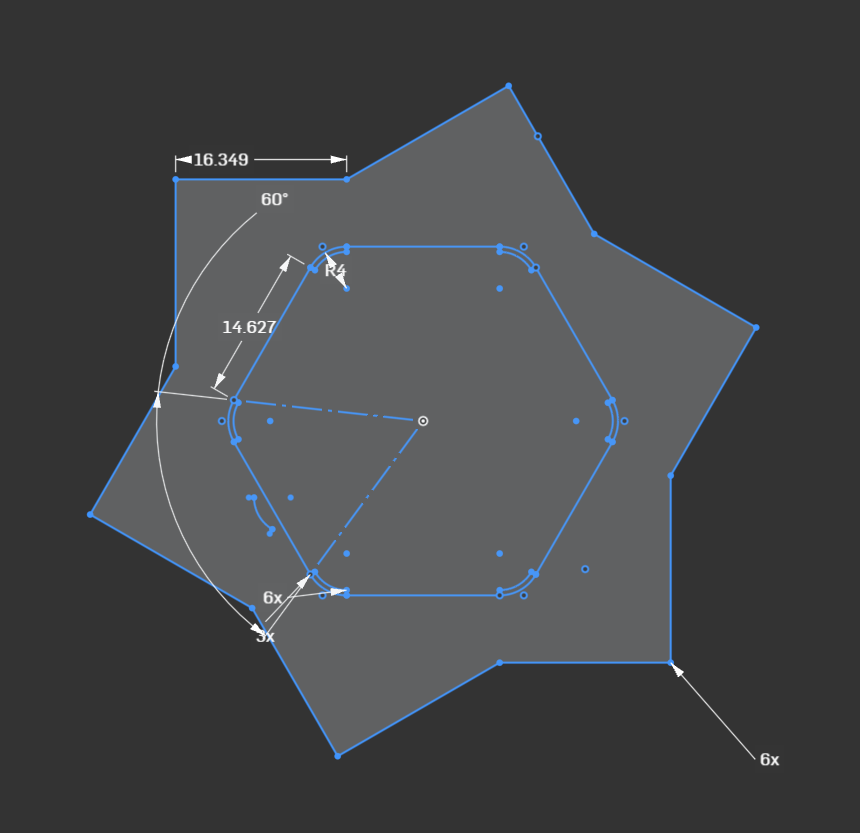
A top-view drawing of my new chamber design, showing the profile, rounded corners and dimensional annotations.
This is part of the chamber and injector revision described below.
View full-resolution drawingI revised the injector from first principles around a hexagonal chamber, with manufacturability and propellant atomization as design goals.
CAD exploration and a Python screening tool connect the geometry to its assumed flow behavior, helping me evaluate a candidate before the next hardware decision.
Read the engineering case studyPassage direction, plate alignment, separate fluid paths, seals and the nozzle interface all have to agree in the assembly.
Keep the intended geometry as a baseline and verify the current part dimensions. Use early calculations to expose assumptions before resizing a design.
My October 8 review records the dimensions, tolerances and assembly risks I assessed. My conclusion was that the earlier design needed a redesign.
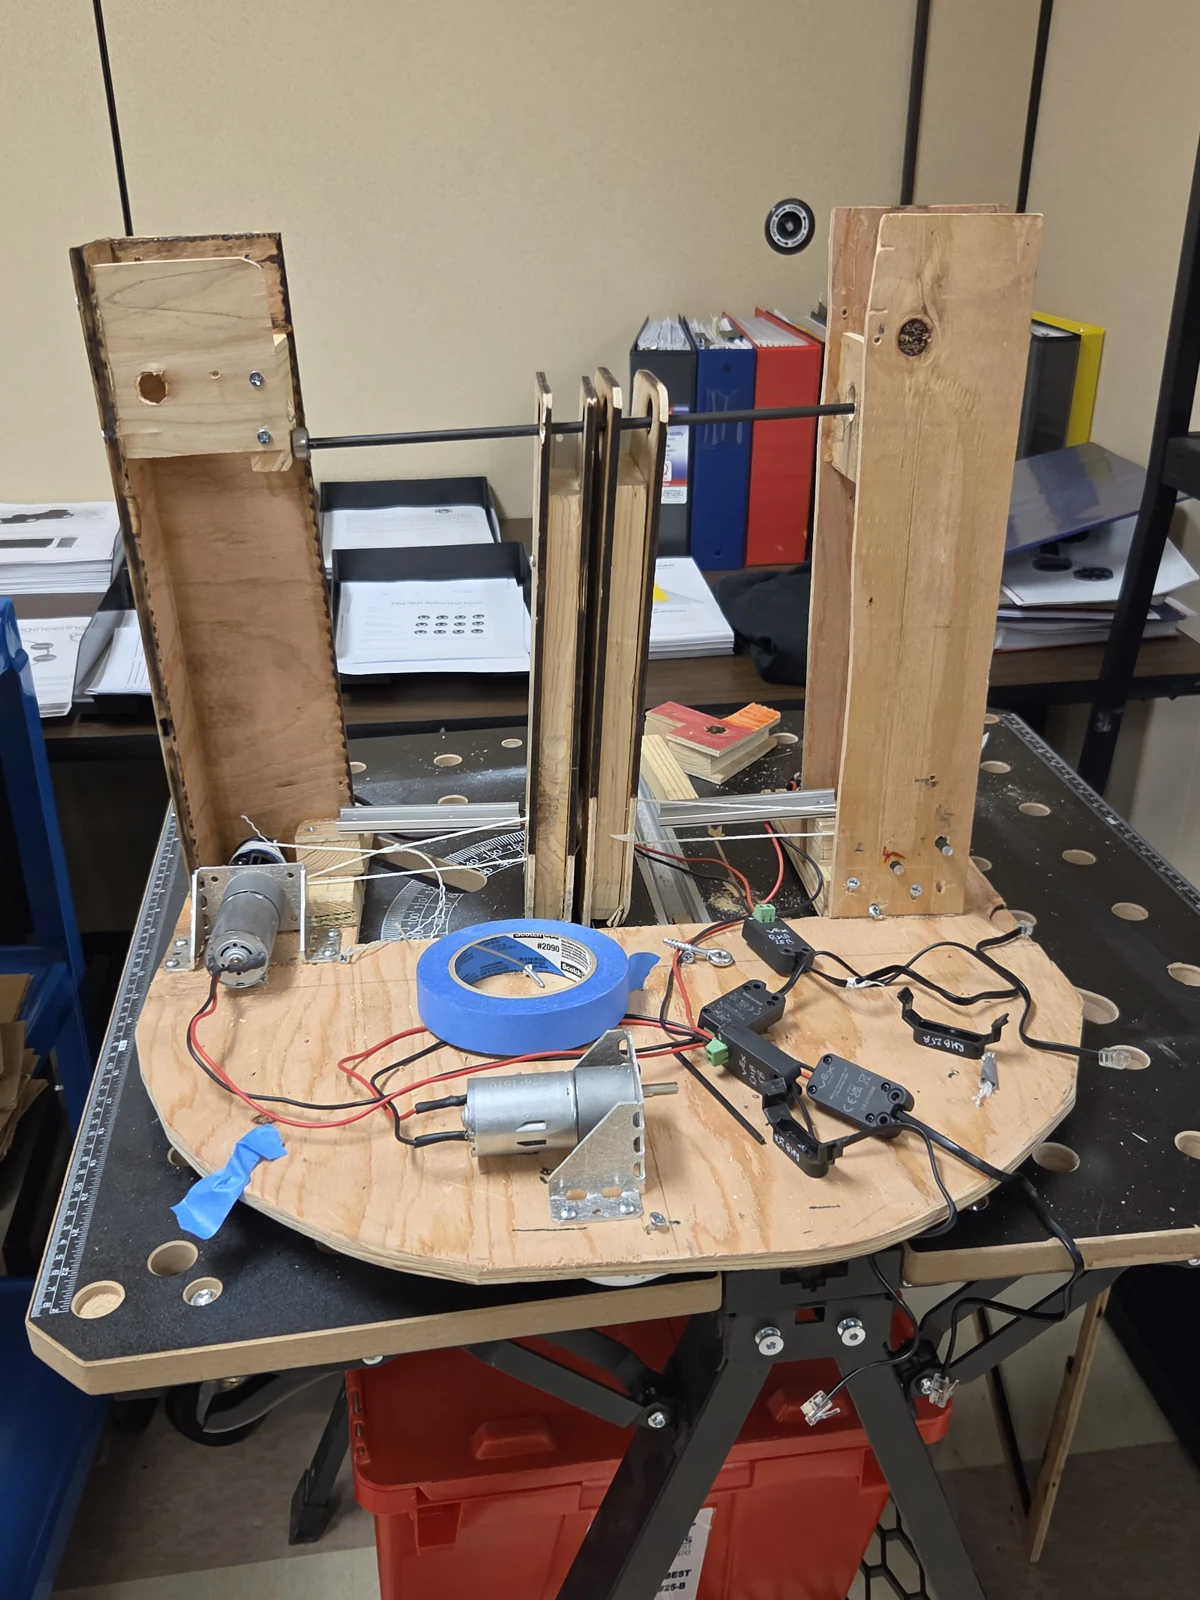
I led the coding team developing manual and autonomous features for our school's BEST Robotics robot, alongside teammates building the hardware.
My contribution: Python driving modes and vision work, with encoder navigation in development.
The control code includes arcade, tank and button-based driving, selectable speeds and camera-based AprilTag detection. The case study follows a specific mode-switching decision through to the source code.
I'm building Sievum, an agentic news and analytical tool that delivers personalized news on niche topics. It brings research and source-backed analysis together so a brief has context beyond a single headline.
The codebase includes topic preferences, company watchlists, a brief reader and archive, source-backed follow-up questions, and scheduled email delivery. My work spans the product interface and the research-to-brief workflow.
The project is in development, with a private beta access flow implemented. The next step is validating the briefing experience with testers: which changes deserve attention, and whether the sources support the summary.
Visit SievumMy independent software studio, with the goal of making software that is both fun to use and useful. It's home to tools for people who build things.
Version control for hardware.
Branching, merging and visual diffs for STEP files, schematics and bills of materials. A software project about tracking both the files and the reasoning behind hardware changes.
Five original UI concepts, from engineering workspaces to playful component kits. I designed the visual systems and built the interfaces.
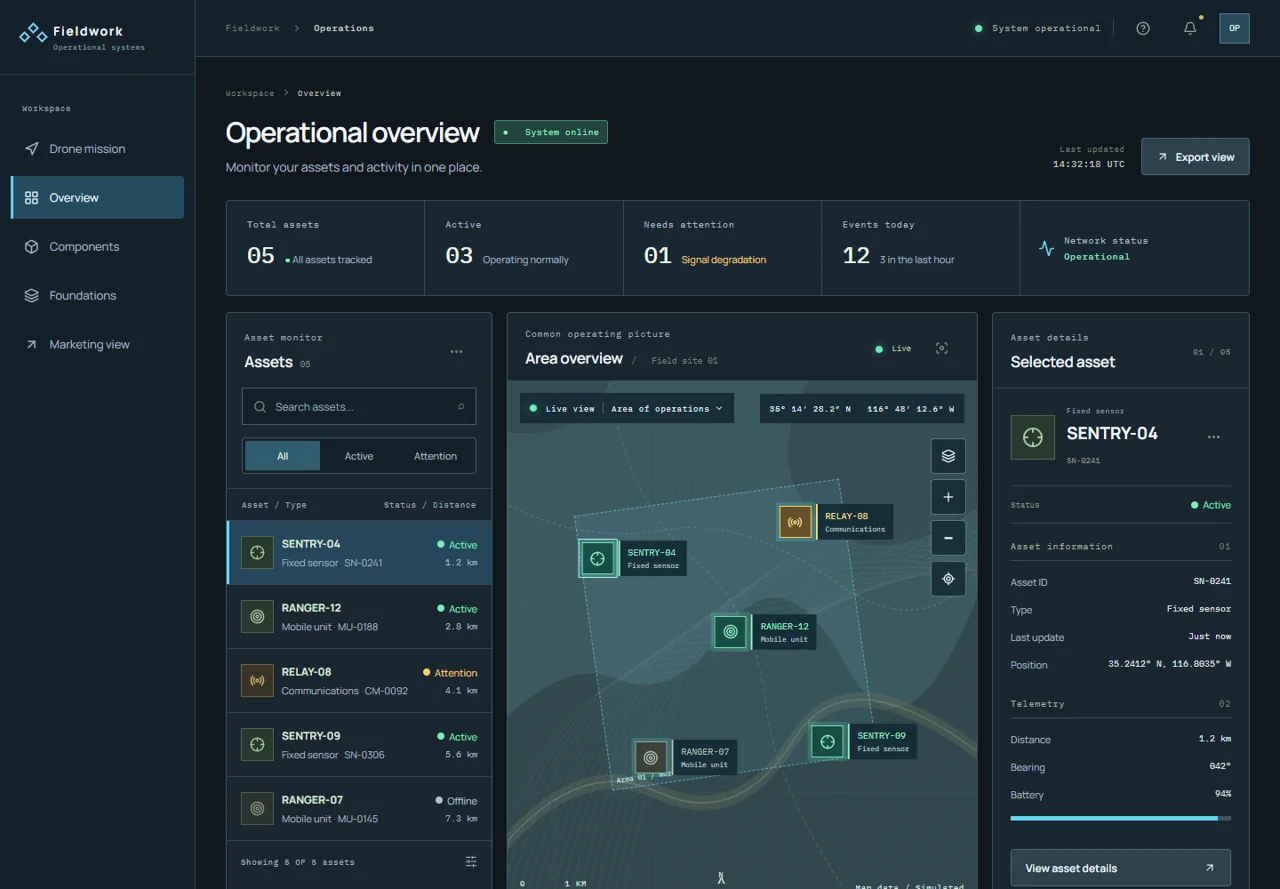 Fieldwork / Operational interface concept
An engineering workspace built around clear hierarchy, status signals and connected detail panels.
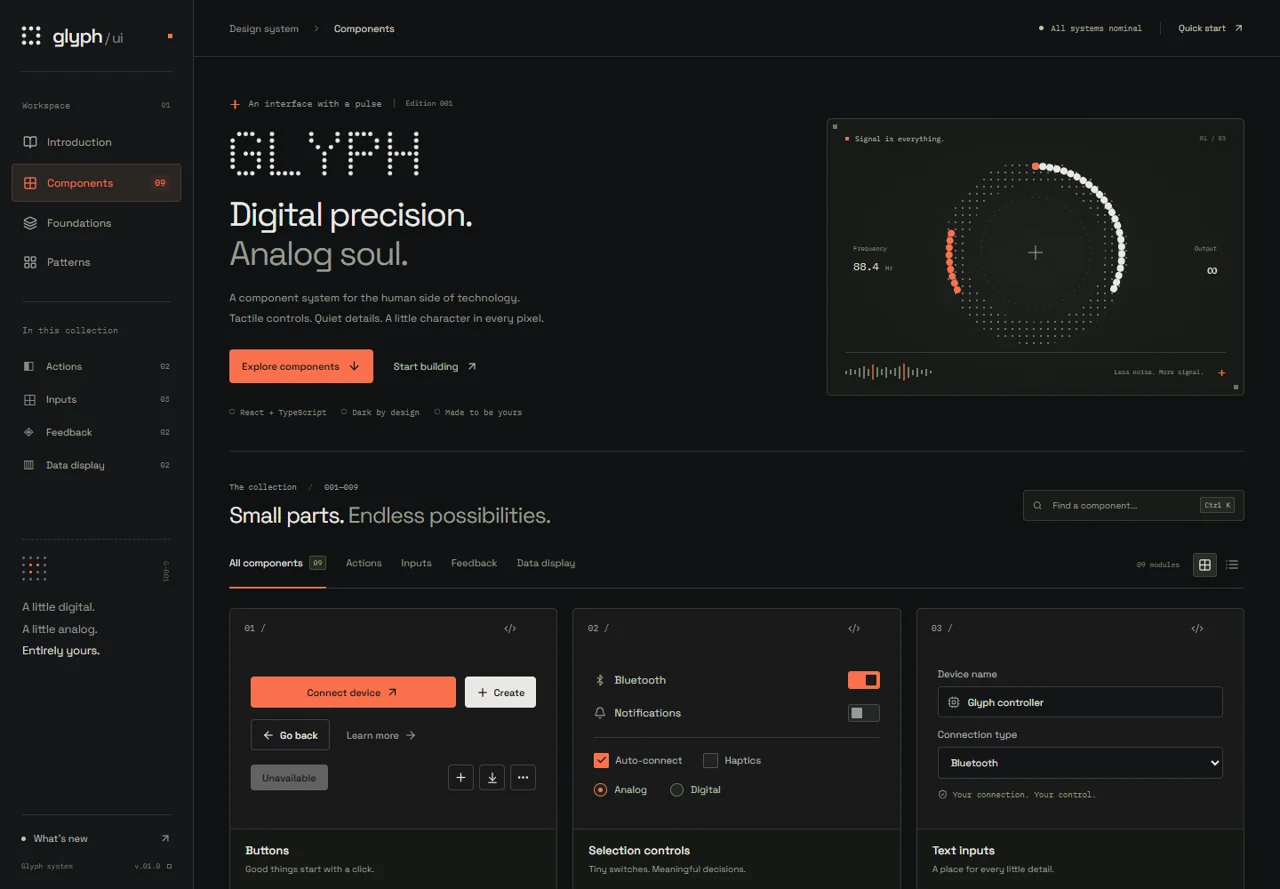 Glyph / Hardware-inspired component kit
Tactile controls, graphite surfaces and dot-matrix details inspired by physical hardware.
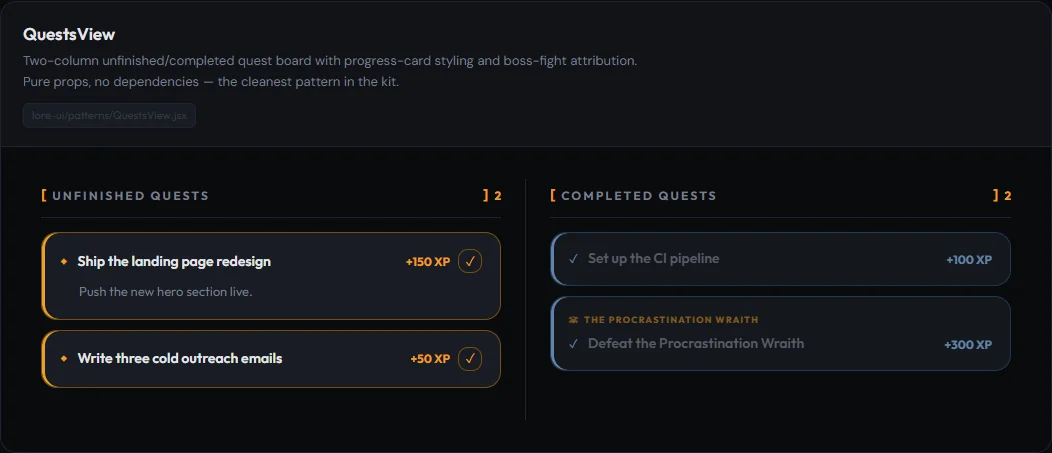
Quest boards, dialogue and navigation patterns extracted into standalone React components.
Visit Lore UI 2 ↗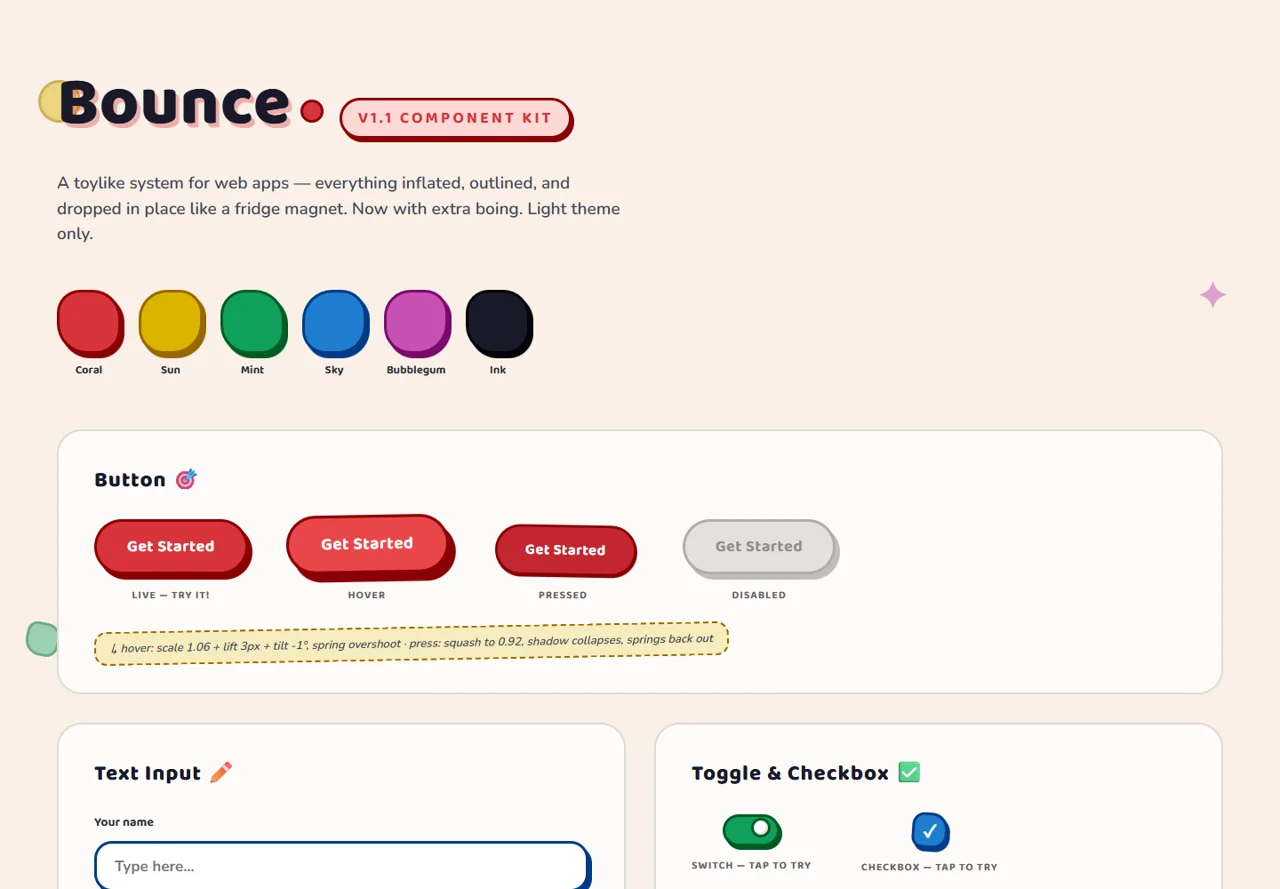
A colorful kit exploring soft shapes, offset shadows and squash-and-stretch interaction.
Visit Bounce ↗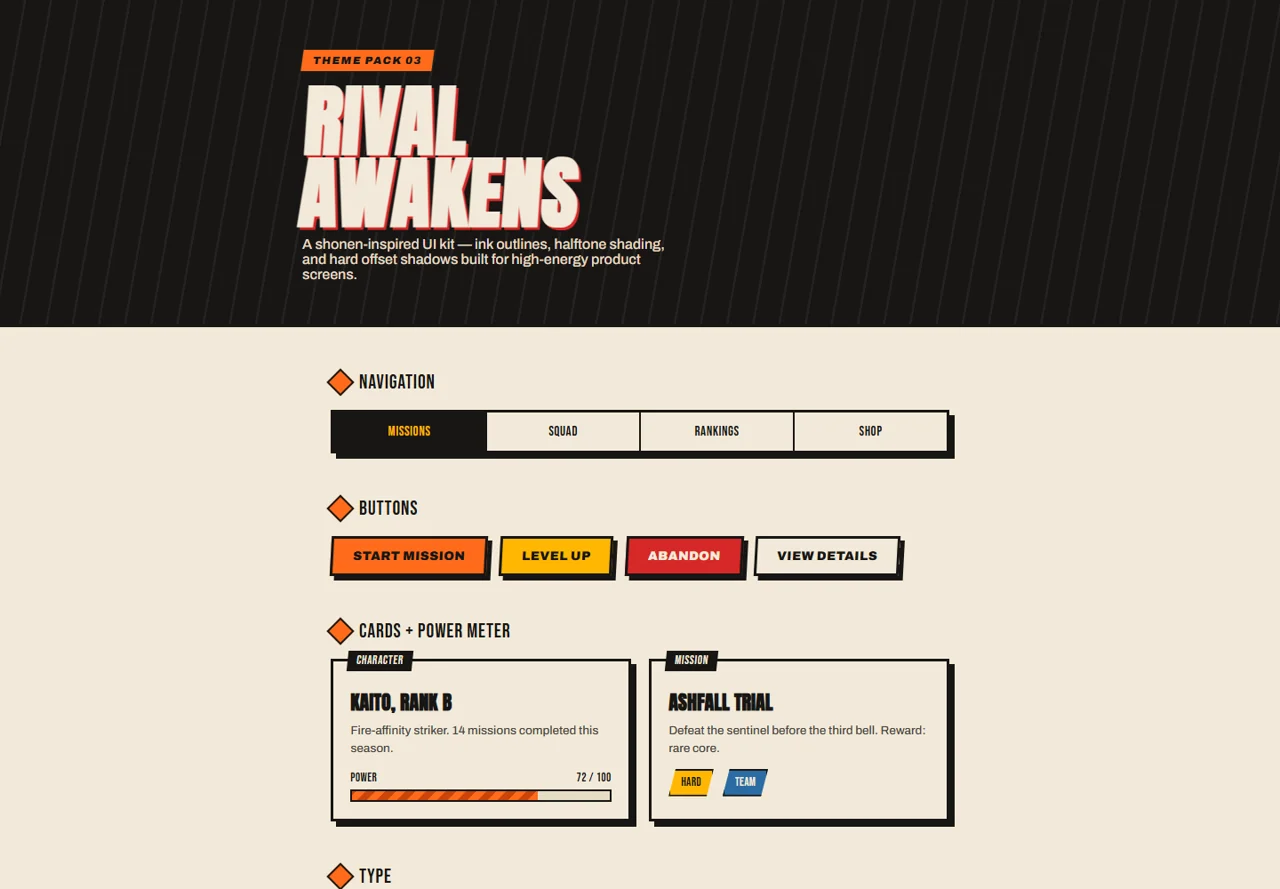
A manga-inspired visual system with ink outlines, expressive type and hard shadows.
Visit Shonen UI ↗
I'm a sophomore at Rock Canyon High School in Colorado. My goal is to understand as much as possible through creation, from the physics of a rocket engine to the details of a software interface.
I like the point where an idea meets a real constraint. The work here includes CAD review, written analysis, code revisions and problems that still need testing. Each project makes me ask a better next question.
Stratum's first-pass study exposed how much a result depends on an unconfirmed dimension or an assumed coefficient. A useful model has to make those limits visible before its output can guide a design.
In the robot code, changing driving modes first stops the motors. Small decisions like that connect what the driver expects with what the software actually commands.
For engineering opportunities, project questions or a conversation.
matthew.liepins@gmail.com